Apollo ↗
Official project, model family or research program. Follow the source for versions, releases and terms.
 Global AI MapAI RESEARCH AND ROBOTICS

◎ Austin, Texas, United States
Humanoid robotics and deployment platforms originating in Austin robotics research.
Official project, model family or research program. Follow the source for versions, releases and terms.
Roles are tied to the linked sources. Paper authors are credited as contributors, which does not establish current employment.
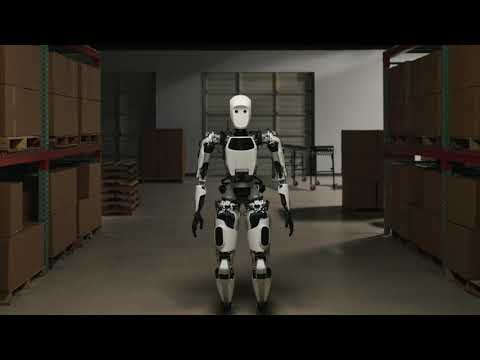 45s
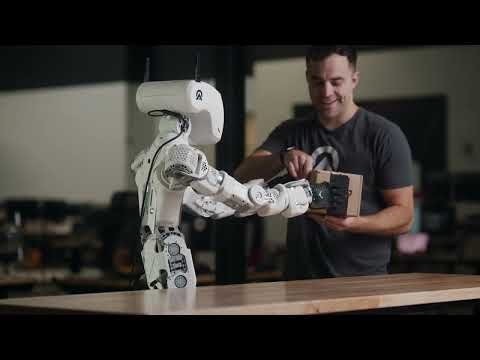 3m41s
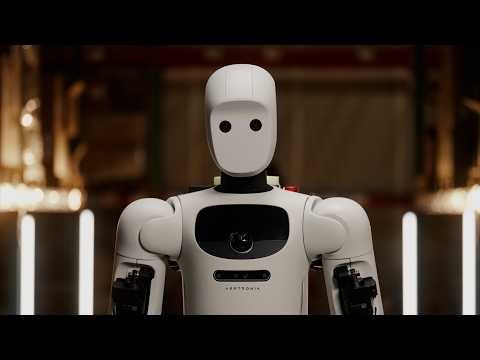 1m15s
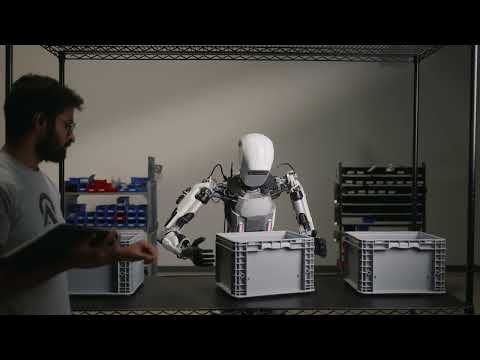 49s
Films are credited to their original channels. Selected presentations may include independent interviews and technical explanations.
The Configuration Manager owns product data governance and configuration control within Teamcenter for Apptronik's robot programs. The role requires at least 8 years of experience in configuration management and hands-on Teamcenter expertise to define release states and BOM structures.
The Controls Engineer - Actuation role involves owning actuator models and control systems for Apptronik's Apollo robot. Candidates must have strong C++ and Python skills, deep motor electromechanics knowledge, and experience with system identification and hardware testing.
Apptronik is seeking early-career, graduate, and experienced talent in robotics, autonomous systems, control theory, and perception to join its team. The role involves working on the Apollo humanoid robot across domains such as perception, control, software systems, and hardware design.
This role leads product management for Apptronik's hardware systems, including robots and peripherals, while building and coaching a team of product managers. The position requires at least 10 years of experience in product management or engineering, including 5+ years leading product managers, and deep fluency in hardware NPI and cost management.
This role leads product management for Apptronik's on and off-robot software, including autonomy, simulation, and cloud tools. The candidate must have 10+ years of experience, 5+ years leading product managers, and deep fluency in the full software lifecycle.
The role is a Director of Technical Accounting & Financial Reporting position based in Austin, TX, focused on establishing the company's technical accounting function. Candidates must have a CPA, 10+ years of experience, and expertise in U.S. GAAP, revenue recognition, and financial reporting.
The Director, Product Learning & Development reports to the SVP of Global Services and Support to build a global learning ecosystem for Apptronik's humanoid robot. The role requires creating certification programs, managing the learning tech stack, and leading a team to ensure operational readiness and customer adoption.
The ECAD Librarian role involves owning and maintaining the Altium component library to ensure schematic symbols, PCB footprints, and 3D models are accurate and standardized. The position requires hands-on expertise with Altium Designer, knowledge of IPC standards, and experience with PLM integration and component data management.
The role involves developing electronics for the Apollo humanoid robot, including designing and testing multi-layer mixed signal PCBAs. Candidates must have strong electrical engineering fundamentals and experience with prototyping, simulation, and hardware debugging.
This role leads a team of software engineers developing real-time control software for humanoid robots. The position requires strong experience in robot control, C++ real-time software, and managing engineering teams.
The Global Supply Manager - Electrical & Electronics owns sourcing strategy and supplier relationships for PCB, PCBA, and electronics components. The role requires at least seven years of experience in strategic sourcing and direct ownership of electronics commodities.
The Hardware Test Engineer role focuses on developing and validating robotic hand hardware for Apptronik's Apollo robot. The position requires hands-on experience in mechanical and electrical testing, test planning, and fixture design within a multidisciplinary R&D team.
This role leads the development of learning-based dexterous control algorithms for Apptronik's humanoid robot, Apollo. The engineer must bridge research and production software, designing scalable architectures for high-DOF manipulation tasks.
This role leads the development of learning-based dexterous control algorithms for Apptronik's humanoid robot, Apollo. The engineer must bridge research and production software, designing scalable architectures for high-DOF manipulation tasks.
The Manager, Manufacturing Engineering leads a team to scale complex hardware from early builds into repeatable production. The role requires 7+ years of manufacturing experience, including 2+ years of leadership, and expertise in NPI, process development, and production readiness.
The Operations Engineering Manager, Supply Chain, is responsible for New Product Introduction readiness, Approved Vendor List governance, and supply chain risk management for Apptronik's humanoid robot. The role requires seven or more years of relevant experience and two or more years of direct people management in operations engineering or hardware manufacturing.
This role leads the development and maintenance of scalable hardware and software test infrastructure for manufacturing and validation of robotic systems. Candidates must have a bachelor's degree and 5+ years of experience leading electromechanical system test development, with formal people-management experience.
This role serves as the technical authority for supplier manufacturing processes, quality systems, and production readiness for electromechanical assemblies. The candidate must have 5+ years of hands-on manufacturing engineering experience and proficiency in PPAP, APQP, and FMEA.
The role is a Senior Technical Program Manager (Operations) reporting to the PMO Director to bridge engineering and operations functions. The position requires 8+ years of technical program management experience and a Bachelor's degree in a related technical discipline.
The Principal Compute & Sensing Engineer serves as the lead architect for the Apollo humanoid robot's compute and sensory backbone. The role requires 12+ years of high-performance hardware design experience and expertise in functional safety architecture.
The Principal Compute & Sensing Engineer serves as the lead architect for the Apollo humanoid robot's compute and sensory backbone. The role requires 12+ years of high-performance hardware design experience and expertise in functional safety architecture.
The Principal People Analytics Specialist builds and leads the People Analytics function to turn workforce data into strategic signals for executive decision-making. The role requires 10+ years of experience in People Analytics, proficiency in SQL and BI tools, and the ability to advise senior leadership on talent strategy and data governance.
The Principal Robotics Machine Learning Engineer develops and deploys ML models for humanoid robot manipulation, managing the full lifecycle from data engine design to on-robot deployment. The role requires 7+ years of experience in robotic manipulation, deep fluency in computer vision and deep learning, and expertise in Python, C++, and PyTorch.
The Product Quality Manager oversees the Quality Team to drive high product quality standards and manage issue resolution for Apptronik's Apollo robot. The role requires experience in complex technical projects, statistical analysis, and managing contract manufacturers during mass production.
The R&D Technician role involves designing, prototyping, and assembling humanoid robots and auxiliary equipment. Candidates must have hands-on electromechanical skills, proficiency with technical drawings, and at least two years of assembly experience.
The role involves creating accurate abstractions for tendon-driven robotic hands and validating them through empirical testing to bridge simulation and physical hardware. Candidates must have 5+ years of experience in robotics, controls, or physical simulation, with proven expertise in sim-to-real transfer and system identification.
This role owns the full lifecycle of Apollo robot demonstrations at Apptronik's California office and at global events. It requires expertise in C++, Python, ROS, and robotics simulation tools to design and execute high-stakes live demos.
The Senior Benefits Specialist role involves owning the design, administration, and execution of benefits programs including health insurance, retirement plans, and wellness initiatives. The position requires an individual-contributor with deep subject-matter expertise to manage vendor relationships, ensure compliance with ERISA and ACA, and resolve complex plan administration issues.
The role involves owning the configuration and administration of Apptronik's ERP systems, partnering with stakeholders to translate requirements into scalable solutions. Candidates must have 5+ years of ERP experience and deep expertise in major platforms like Microsoft Dynamics 365, Salesforce, SAP, or Oracle.
This role leads a team responsible for PLM, MES, and Quality systems to support the transition of Apptronik's humanoid robot from prototype to volume production. The candidate must have 6+ years of enterprise systems leadership experience, including at least 2 years of direct people management, and demonstrated ownership of full-lifecycle system implementations.
The Senior Compensation Business Partner supports Apptronik's Total Rewards team by conducting complex compensation analyses and managing pay strategy. The role requires 5+ years of compensation experience, advanced Excel skills, and knowledge of compensation compliance and market data sources.
The role involves designing custom BLDC/PMSM motors for humanoid robots, setting performance metrics, and leading electromagnetic simulations. Candidates must have an MS or PhD in a related engineering field and 5+ years of experience in electric machine design.
The role involves developing electronic systems for the Apollo humanoid robot from ideation through mass production. Candidates must have 4+ years of experience in electrical engineering and proven success shipping electronics products.
The role involves owning electronic systems for the Apollo humanoid robot's end effectors, from ideation through mass production. Candidates must have at least 8 years of experience in electrical engineering and expertise in PCB design, motor drives, and prototyping.
The role involves driving electronics development for the human-robot interface of the Apollo robot, focusing on display and LED lighting systems. Candidates must have proven experience designing audio and display systems, with at least five years of industry experience in display or LED lighting electronics.
The role involves driving electronics development for the power electronics and power distribution subsystems of the Apollo humanoid robot. Candidates must have strong backgrounds in power electronics, batteries, battery chargers, and PCBA design.
The role involves owning the board support package and OS configuration for the NVIDIA Jetson Thor platform in humanoid robots. Candidates must have at least five years of embedded systems experience with Linux or QNX and strong OS-level skills.
The role involves developing and optimizing actuation and motor control firmware for humanoid robots, including brushless motor control and real-time performance. Candidates must have a Bachelor's degree in engineering and at least five years of experience in production-grade embedded software.
The Senior Firmware Engineer role involves developing and maintaining embedded software for humanoid robot hands, focusing on motor control, sensor integration, and real-time communications. Candidates must have experience with C/C++, TI C2000 microcontrollers, and EtherCAT, along with familiarity with safety-critical design standards.
The role involves owning design validation, reliability, and production test for electronic components such as PCBAs, wiring harnesses, sensors, and compute modules. Candidates must have hands-on experience with bench equipment, production test methods, and HALT/HASS, along with strong debugging skills to root-cause hardware failures.
The Senior Manager of Hardware Connectivity leads a team designing the data transmission systems for the Apollo humanoid robot. The role requires 10+ years of hardware engineering experience and 4+ years of people management, with expertise in RF, signal integrity, and EMI/EMC.
The Manufacturing Engineer serves as the bridge between product design and mass production, developing and validating robust manufacturing processes for new hardware. The role requires 5+ years of experience in manufacturing engineering, NPI, or complex hardware industrialization, along with proficiency in CAD and DFM/DFA.
The Senior Mechanical Engineer role involves designing and developing Apollo humanoid robots across the full product lifecycle, from concept to production. Candidates must have strong engineering fundamentals, experience with DFMA and manufacturing, and the ability to own significant subsystems with minimal supervision.
The Senior Mechanical Engineer leads the design and development of battery systems and docking infrastructure for the Apollo humanoid robot. The role requires 6+ years of mechanical design experience, proficiency in CAD, and the ability to collaborate across engineering teams to ensure safety and manufacturability.
The role involves leading the detailed design and analysis of electric actuators for a humanoid robot system. Candidates must have 6+ years of experience in actuation or robotic systems and proficiency in CAD software.
The Senior PCBA Design Engineer role involves owning PCB schematic capture and layout in Altium Designer, with a focus on power electronics and high-speed digital design. Candidates must have at least five years of experience and a Bachelor's degree in Electrical Engineering or equivalent.
The Senior Perception Hardware Engineer role focuses on sensor calibration for Apptronik's humanoid robot Apollo. The position requires designing physical fixtures, writing calibration algorithms, and building scalable factory processes for multi-modal perception systems.
This role involves developing and optimizing perception and SLAM pipelines for humanoid robots, focusing on visual-inertial odometry, multi-sensor fusion, and deep learning models. Candidates must have an MS/PhD and 3-5+ years of experience shipping perception or SLAM systems in robotics or real-time vision applications.
The Senior Product Manager role focuses on driving the product vision and execution for human robot interaction features on Apptronik's Apollo robot. Candidates must have 7+ years of product management experience and strong analytical skills to translate market demands into executable roadmaps.
The role involves driving the product vision and roadmap for simulation platforms used in robot fleets. Candidates must have experience managing simulation environments and translating technical insights into business impact.
The role involves owning the product direction and roadmap for Apptronik's humanoid robot platform, managing the deployed fleet, and driving cost-down initiatives. Candidates must have at least five years of product management experience and a technical degree, with strong analytical and communication skills.
This role involves driving the product vision and roadmap for perception and navigation software on Apptronik's humanoid robot. Candidates must have 7+ years of product management experience and strong expertise in autonomy, field testing, and safety.
The Senior Product Manager will own the teleoperation product roadmap and interface for Apollo's humanoid robot. The role requires 7+ years of product management experience, human factors expertise, and experience with real-time operator interfaces or teleoperation.
The Senior Reinforcement Learning Engineer develops and deploys advanced RL algorithms for humanoid robot locomotion and manipulation. The role requires 5+ years of experience with RL frameworks, Python, C++, and sim-to-real transfer, plus mentoring responsibilities.
The Senior Reinforcement Learning Engineer develops and deploys advanced RL algorithms for humanoid robot locomotion and manipulation. The role requires 5+ years of experience with RL frameworks, Python, C++, and sim-to-real transfer techniques.
The Senior Site Reliability Engineer manages and scales the DevOps platform, including Kubernetes clusters and CI/CD infrastructure, to ensure reliability and safety for robot software releases. The role requires deep Linux and Kubernetes expertise, along with skills in infrastructure as code, observability, and debugging production issues.
The role involves building ML infrastructure platforms for data curation, pipelines, and model evaluation at multi-terabyte scale. Candidates must have deep experience in large-scale data pipelines, annotation, or evaluation, plus strong Python and cloud skills.
The role involves defining and testing the reliability of complex electromechanical systems, including setting MTBF targets and leading root-cause investigations. Candidates must have experience leading reliability programs, designing tests, and mentoring engineers.
The role leads system-level integration and validation of soft goods, robotic gloves, and grip surfaces for Apptronik's humanoid robot, Apollo. Candidates must have strong mechatronics and systems engineering fundamentals with hands-on expertise in flexible assemblies and embedded tactile sensors.
The Senior Systems Engineer role focuses on integrating and developing the humanoid robot chassis, which serves as the structural and electromechanical backbone. The position requires strong experience in robotics systems design, structural mechanics, and cross-functional collaboration to ensure performance, safety, and manufacturability.
The Senior Wire Harness Engineer designs, routes, and validates complex wire harnesses for Apptronik's humanoid robot Apollo. The role requires strong electrical and mechanical integration skills, E-CAD proficiency, and experience with high-speed data and power distribution in dynamic environments.
The Software Engineer role focuses on implementing reinforcement learning and control algorithms for high-DOF robotic hands. Candidates must have experience with dexterous manipulation, Python, C++, and deploying algorithms on physical hardware.
This role develops and deploys learning-based manipulation policies for Apptronik's humanoid robot Apollo, focusing on post-training methods for real-world tasks. The engineer must bridge research and production software, collaborating with simulation, data, and hardware teams to ensure reliable deployment.
The Senior Manager of Inventory Management, Logistics, and Procurement leads and scales operational capabilities for inventory, warehouse, logistics, and supplier management. The role requires 10+ years of supply chain experience, 5+ years of people management, and a Bachelor's degree to improve inventory accuracy and material availability in a manufacturing environment.
The role involves owning safety assurance for software and AI in humanoid robots, including architecture analysis and verification evidence. Candidates must have 8+ years of experience with safety-critical software, IEC 61508-3, and AI safety standards.
The Staff Drivetrain Engineer role involves designing, building, and testing drivetrain technologies for electric actuators in Apptronik's humanoid robot. Candidates must have 8+ years of experience in drivetrain development and proficiency in gear design software and CAD.
The role involves owning electronic systems for the Apollo humanoid robot from ideation through mass production. Candidates must have 8+ years of experience in electronics development and proven success shipping products to market.
The role involves leading the architectural design and implementation of a next-generation compute solution for a humanoid robot platform. Candidates must have 10+ years of experience in embedded systems or robotics compute design and expertise in functional safety standards.
The role involves leading the architectural design and implementation of a next-generation compute solution for a humanoid robot platform. Key requirements include 10+ years of experience in embedded systems or robotics compute design and expertise in functional safety standards.
The role involves architecting the electronics and FPGA stack for Apollo's sensor bridge, including requirements, RTL development, and production transition. Candidates must have strong FPGA hardware design experience and at least 8 years in Electrical Engineering.
The role involves architecting the electronics and FPGA stack for Apollo's sensor bridge, including requirements, RTL development, and production transition. Candidates must have strong FPGA hardware design experience and at least 8 years in Electrical Engineering.
The Staff Mechanical Engineer provides technical leadership for the design and development of Apollo humanoid robots across their full lifecycle. The role requires deep expertise in mechanical systems, DFMA, and FEA, along with experience mentoring engineers and leading cross-functional design efforts.
The role leads the structural design and architecture of a next-generation robotic hand for a humanoid platform, focusing on dexterous manipulation in unstructured environments. Candidates must have 8 years of mechanical design experience in complex robotic systems and expertise in surfacing tools like SolidWorks.
The role is a Staff Mechanical Engineer serving as the technical lead for the Apollo robot's upper body, including the torso, head, and arms. The position requires 8 years of mechanical design experience in complex robotic systems and expertise in kinematics, high-density integration, and Class-A surfacing.
The Staff MLOps Engineer owns the technical direction of Apptronik's MLOps platform, managing dataset lifecycle, experiment tracking, model registry, and serving paths for the Apollo robot. The role requires 8+ years of software engineering experience, deep proficiency in Python and a systems language, and expertise in Kubernetes and production ML platform architecture.
The Staff People Technology Specialist manages Workday functional configuration, with a primary focus on payroll setup, compliance, and system maintenance. The role requires five to seven years of Workday experience, including two years with payroll, and a bachelor's degree in IT or a related field.
The Staff Perception Hardware Engineer leads the physical integration and validation of Apollo's perception hardware systems, including cameras and optics. The role requires 8+ years of experience in shipping complex vision hardware and hands-on troubleshooting of high-speed data links.
The Staff Perception Hardware Engineer leads the physical integration, validation, and production of Apollo's perception hardware systems. The role requires 8+ years of experience in shipping complex vision hardware, along with expertise in high-speed signal debugging, optical tuning, and cross-functional technical leadership.
This role involves driving the product vision and roadmap for Apptronik's Apollo humanoid robot, focusing on integrating foundation models into its autonomy stack. Candidates must have 7+ years of product management experience and strong knowledge of robot learning techniques like imitation and reinforcement learning.
The Staff Simulation Engineer role focuses on developing a high-performance core simulation platform for RL training and controls validation. The position requires strong C++ and Python skills, robotics fundamentals, and experience with modern simulators and cloud-based parallel computing.
This role involves leading the Motion Control & Planning team to develop whole-body control and learning-based systems for Apptronik's humanoid robots. Candidates must have 8+ years of experience in robot controls, with expertise in C++, reinforcement learning, and deploying algorithms on physical hardware.
This role involves leading the Motion Control & Planning team to develop whole-body control and learning-based systems for humanoid robots. Candidates must have deep robotics fundamentals, expertise in whole-body control, and strong real-time C++ and Python skills.
This role requires a technical authority for humanoid robot safety, responsible for authoring system safety architectures and cases. Candidates must have 12+ years of experience, including 7+ in functional or system safety for complex robotic products.
This role owns product safety and regulatory compliance for a humanoid robot, including electrical safety, EMC/EMI, battery, and radio standards. The engineer leads certification engagements and manages the compliance roadmap across multiple global markets.
This role is a Staff Technical Program Manager position in the PMO department, serving as the first TPM in the Sunnyvale office. The candidate must lead cross-functional programs for MLOps and perception systems while managing strategic partnerships and establishing program structures for the new site.
The role involves owning design verification and NPI testing for custom actuator systems, requiring hands-on experience across mechanical, electrical, firmware, and software domains. Candidates must independently drive actuator characterization, develop test methods for production handoff, and diagnose hardware issues across the electromechanical stack.
The Staff Video Producer role involves creating cinematic narratives for Apptronik's robotics products, managing video projects from pitch to delivery. Candidates must have 10+ years of experience in writing, producing, and directing video content, with strong skills in creative direction and production management.
The Staff Wire Harness Engineer serves as the principal technical authority for the humanoid robot's interconnect architecture, defining power and data distribution strategies. The role requires expert-level knowledge of high-speed data and high-power distribution, along with 8+ years of experience in complex electromechanical systems.
The Strategy & Operations Associate is a high-potential generalist in Customer Transformation who structures ambiguous problems and builds models for pricing and market sizing. The role requires 2-4 years of experience in consulting or strategy, strong quantitative skills, and the ability to deliver executive-ready recommendations.
The role is a Contract Talent Acquisition Recruiter responsible for full-cycle searches across technical and corporate roles. The position requires 5+ years of recruiting experience, proficiency with applicant tracking systems, and the ability to manage multiple complex searches.
Current official-feed vacancies. Follow each job for its complete description and application terms.
B Capital co-led the initial round. Apptronik’s March 2025 update reported a $403 million Series A in total; that total is not attributed to this investor alone.
PRIMARY SOURCE ↗
Capital Factory co-led the initial round. Apptronik’s March 2025 update reported a $403 million Series A in total; that total is not attributed to this investor alone.
PRIMARY SOURCE ↗
Google participated in the round. Apptronik’s March 2025 update reported a $403 million Series A in total; that total is not attributed to this investor alone.
PRIMARY SOURCE ↗Profile reviewed 2026-10-30. Approximate city-level marker.